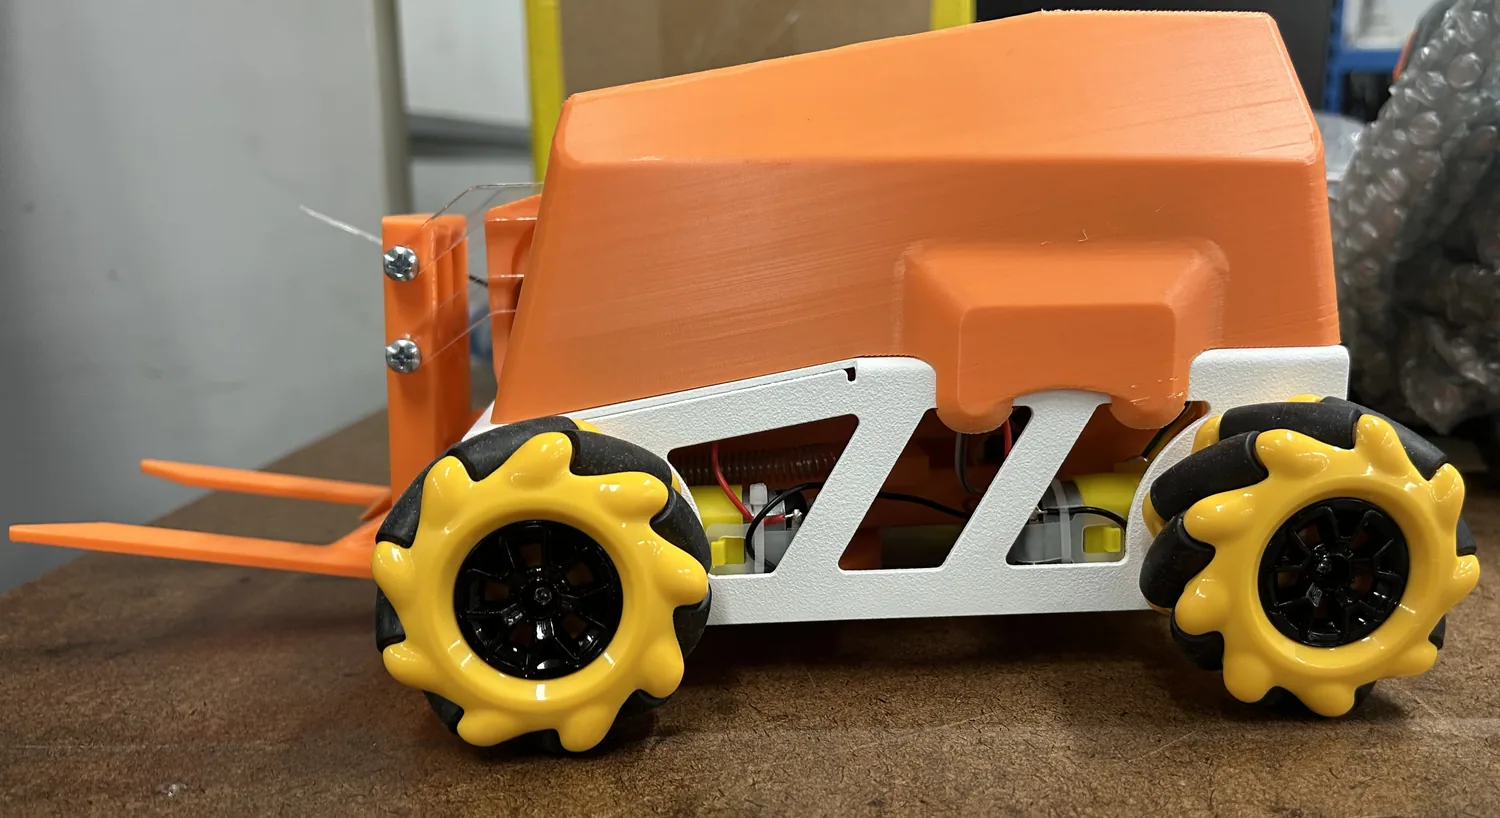
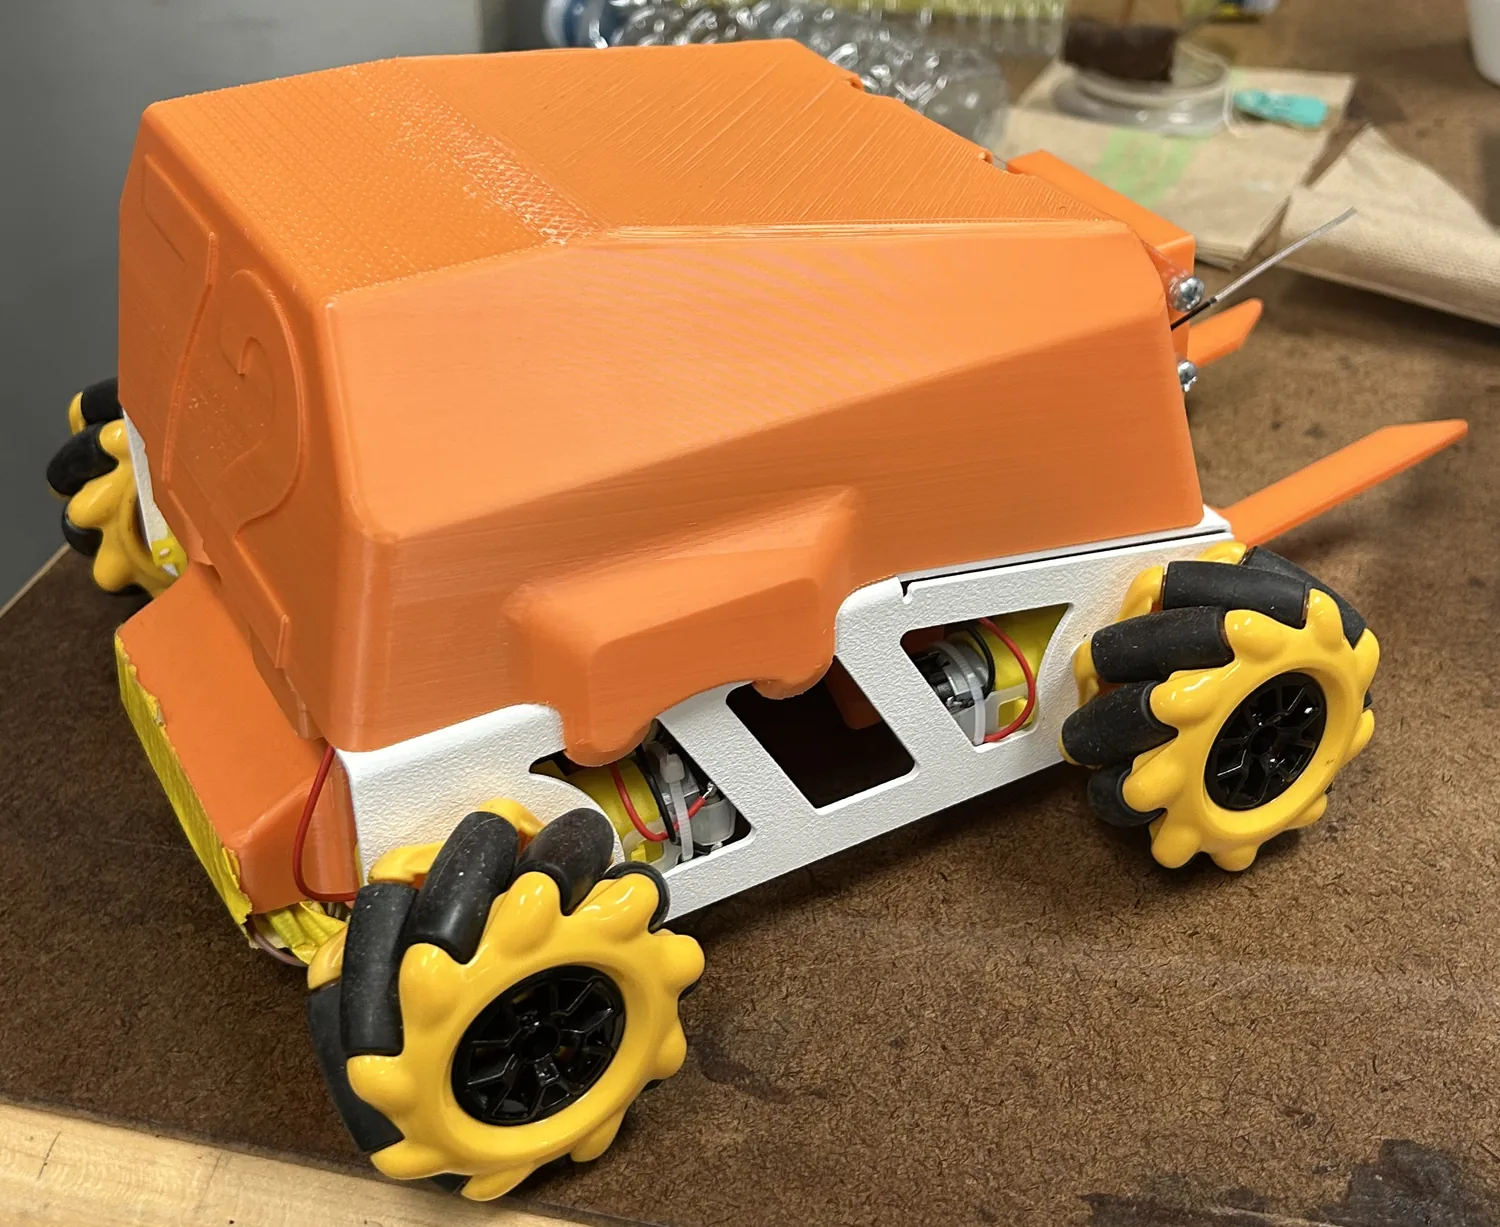
A remote-controlled robot had to run a course while handling a miniature soccer ball. Our answer: an omnidirectional base, a motorized fork and a cam-and-spring kicker.
Role
Mechanical design, CAD, fabrication and reports
Context
Team of 6, 130-hour project
Year
2025
Tools
CATIA, SolidWorks, Fusion 360, 3D printing, laser cutting, machining
2nd in designand 7th in performance, among more than 30 competing teams.
Loading 3D model
Full assemblyDrag to rotate · hover a part
01 · Starting pointThe robot in pieces
Every part comes from the original CATIA model.
02 · Chassis and driveAn omnidirectional base
Four TT motors and mecanum wheels let it move in any direction.
03 · MechanismsKicker and fork
A cam compresses the piston spring and a servo drives the fork.
04 · Power onReady to shoot
The wheels spin and the piston strikes the ball.
A cam-driven kicker
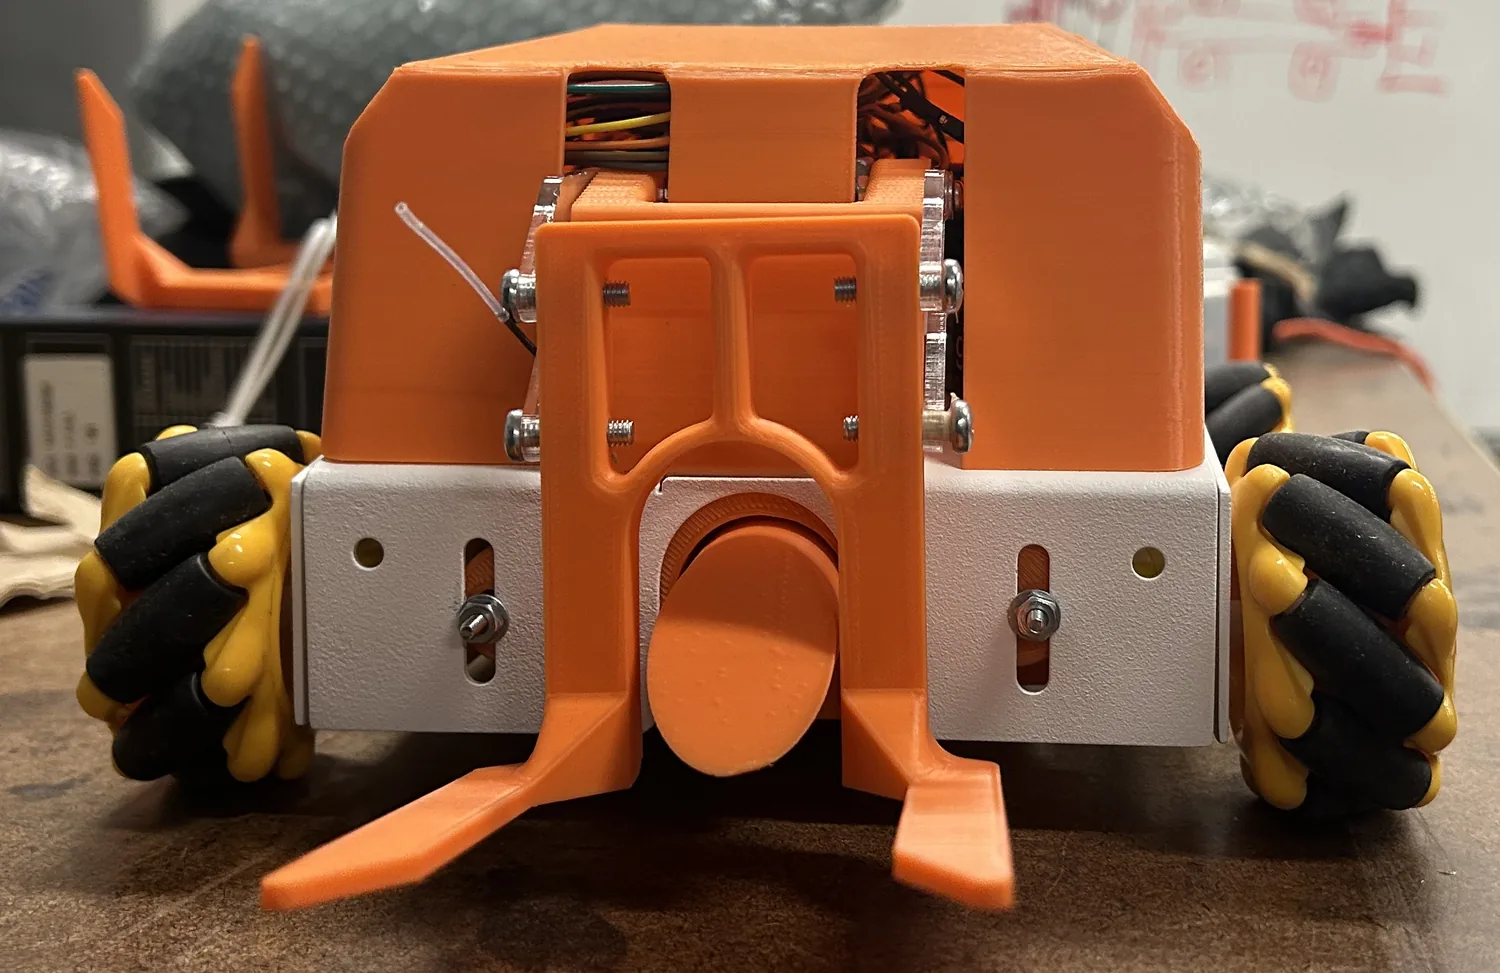
The kicker uses a guided piston. A motor-driven cam gradually compresses a spring, then releases it all at once to strike the ball.
Custom-modelled cam and piston guide
Fork driven by an SG90 servo
Mecanum wheels to move without turning
Front view: fork and kicker mechanism.
From model to competition
We compared several concepts as a team, then purchased, printed, laser-cut and machined the required parts. The cut sheet-metal chassis carries everything, and the printed shell protects the electronics.
Modelling in CATIA, SolidWorks and Fusion 360
Technical reports, analysis files and presentations